Welcome to Computational Engineering Laboratory web site

Faculty of Engineering, University of Rijeka

Lecture: Autonomous UAV system for oceanic search and rescue

We invite you to a lecture: “Autonomous UAV system for oceanic search and rescue”

Prof. Stefan Ivić, PhD, head of the research project funded by the Croatian Science Foundation titled “Autonomous UAV system for oceanic search and rescue” (AOSeR), will present the project results, including an overview of its implementation and highlighting the key contributions of the conducted research.

During the five-year project, algorithms for ergodic control of unmanned aerial vehicles were developed and refined for autonomous search operations on land and at sea. The research was supported by numerous field experiments. More than 140 volunteers and staff members participated in field experiments conducted in the Učka Nature Park area.
Offshore Wind Farms Summer School

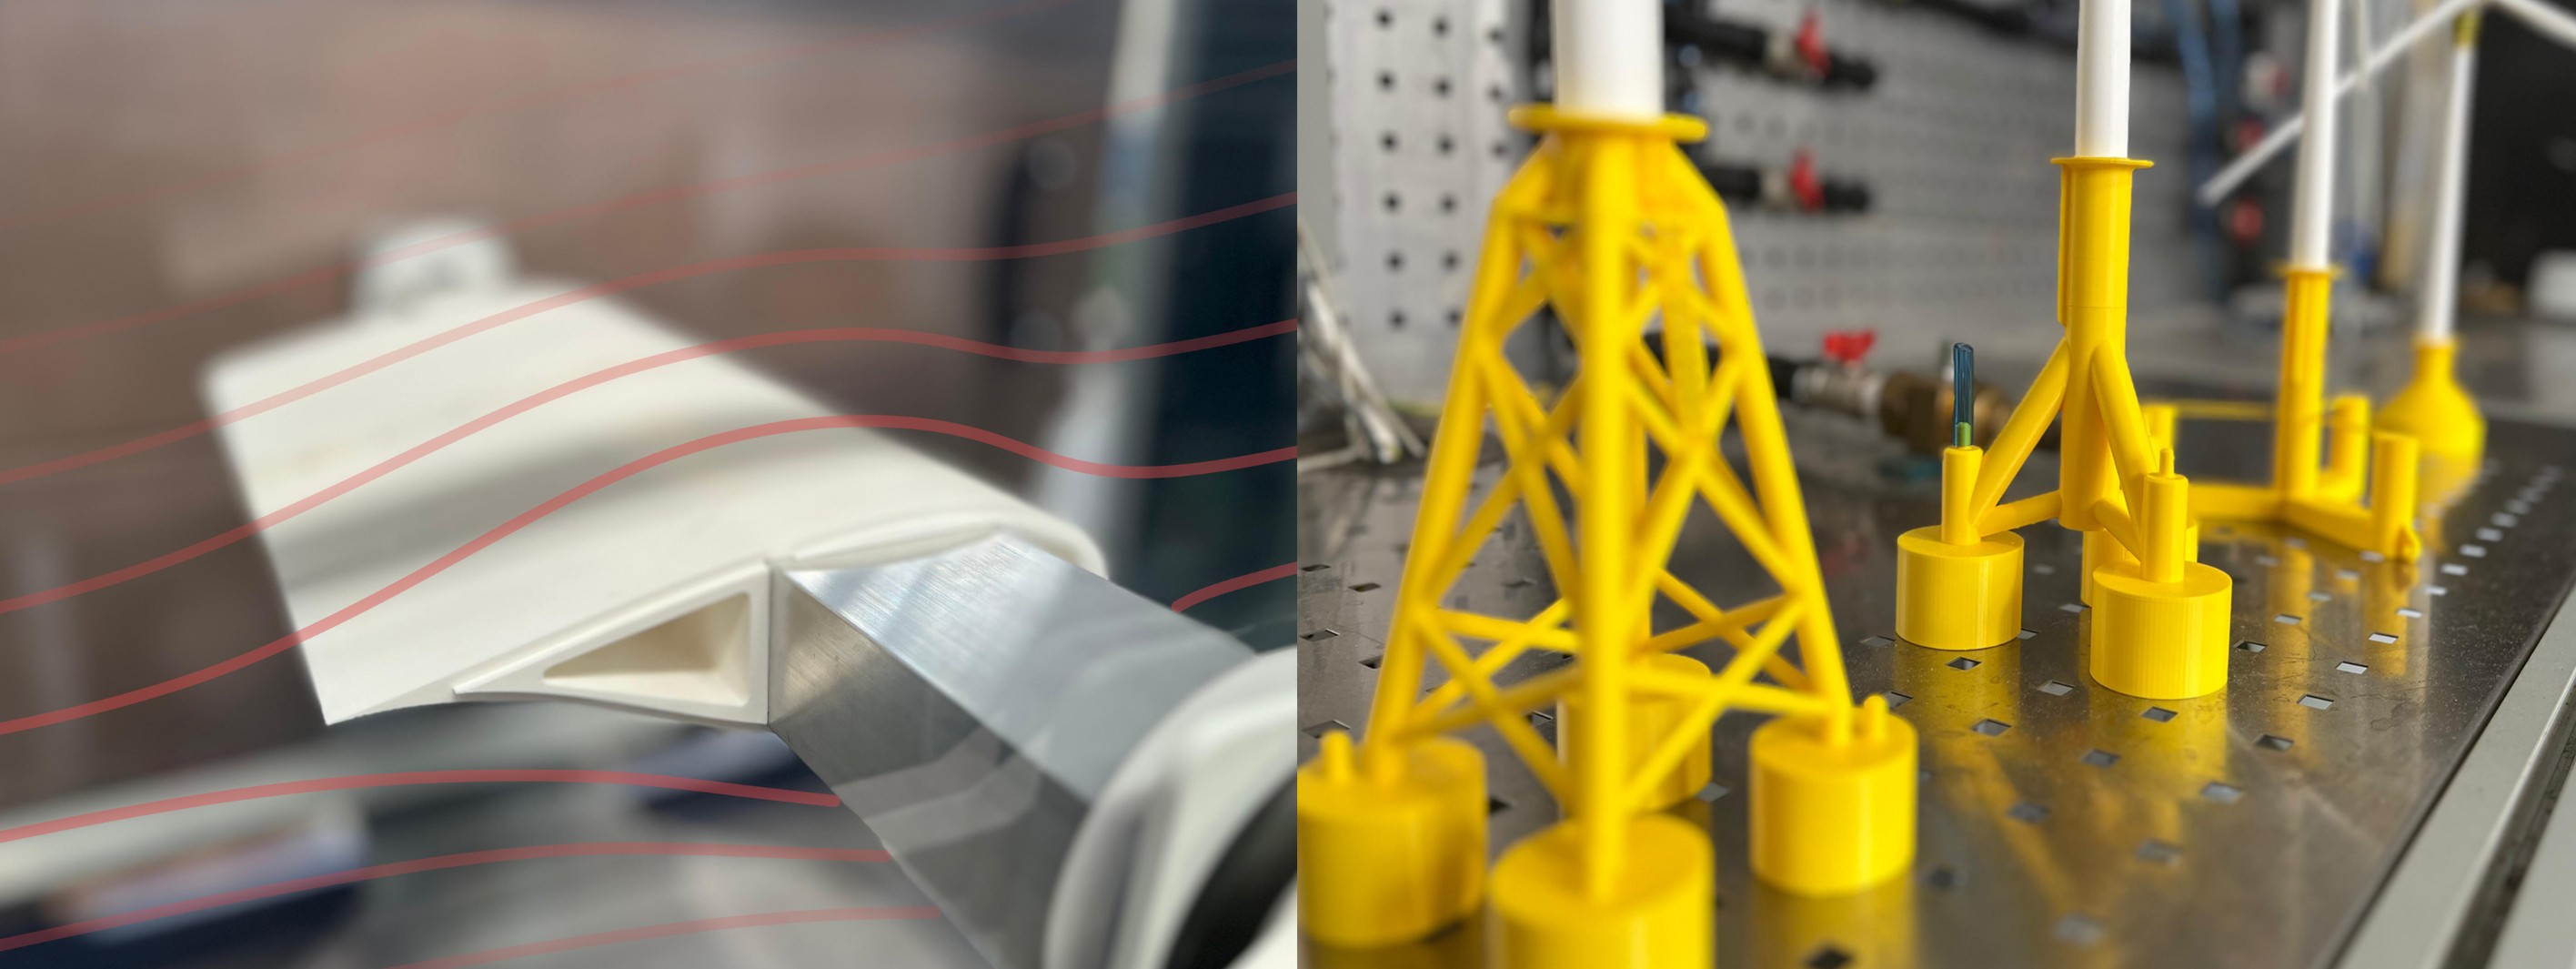
As part of the Blue Economy sYnergies fOr sustaiNable Development (BEYOND) project, Summer School on Offshore Wind Farms – Technical Aspects will be organized at the Faculty of Engineering in Rijeka by members of Computational Engineering Lab.

This Summer School provides an intensive, interdisciplinary introduction to offshore wind farms, combining technical, environmental, and industry perspectives. Through expert lectures and panel discussions, hands-on workshops, computer simulations, wind tunnel demonstrations, and 3D modelling, participants will gain practical insight into the design, operation, and impacts of offshore wind energy systems.

2nd Computational Engineering Seminar

We are pleased to announce our next seminar, which will take place on Wednesday, January 28th, at 13:00 in the Computational Engineering Laboratory (Room L-10).

Two exciting presentations are scheduled:

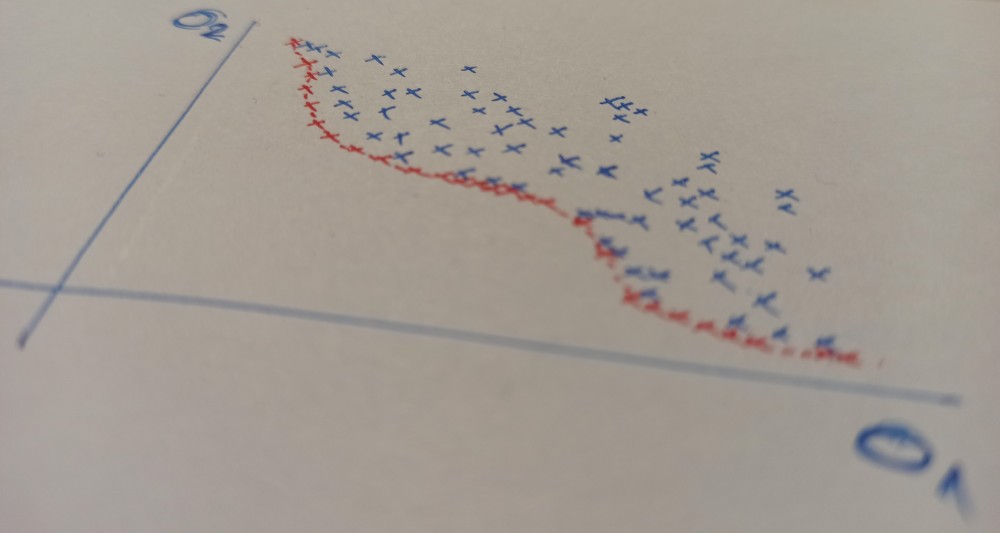
  • Bojan Crnković – Introduction to CMA-ES
  • Ante Sikirica – Pareto Optimality and NSGA-II

All interested researchers and students are warmly invited to attend. We look forward to your participation!

A paper accepted for publication in IEEE Transaction on Robotics

Happy to share that our paper Probabilistic Modeling and Control for Multi-UAV Search Over Uneven Terrain, by Luka Lanča, Karlo Jakac, and Stefan Ivić, has been accepted for publication in IEEE Transactions on Robotics and is now available on IEEE Xplore.

In this work, we study how multiple UAVs can cooperatively search complex, uneven terrain more effectively. The proposed control framework estimates target detection probability under uncertainty and adapts the search strategy accordingly. The approach combines machine-learning–based detection, ergodic search control, and MPC-based altitude and speed control, while accounting for UAV motion and sensing constraints, detector performance, and terrain features.

Computational engineering seminar

We invite all researchers and students to attend our upcoming seminar on Wednesday, December 10th, at 14:00 in the Computational Engineering Laboratory (Room L-10).

Presentations will include:

  • Indago: A Developer and User Perspective
  • Benchmarking Optimization Methods

We look forward to your participation!